Environment IDs
AM-Bench registers Isaac Lab direct environments with IDs that expose the task, robot profile, action interface, and controller selection.
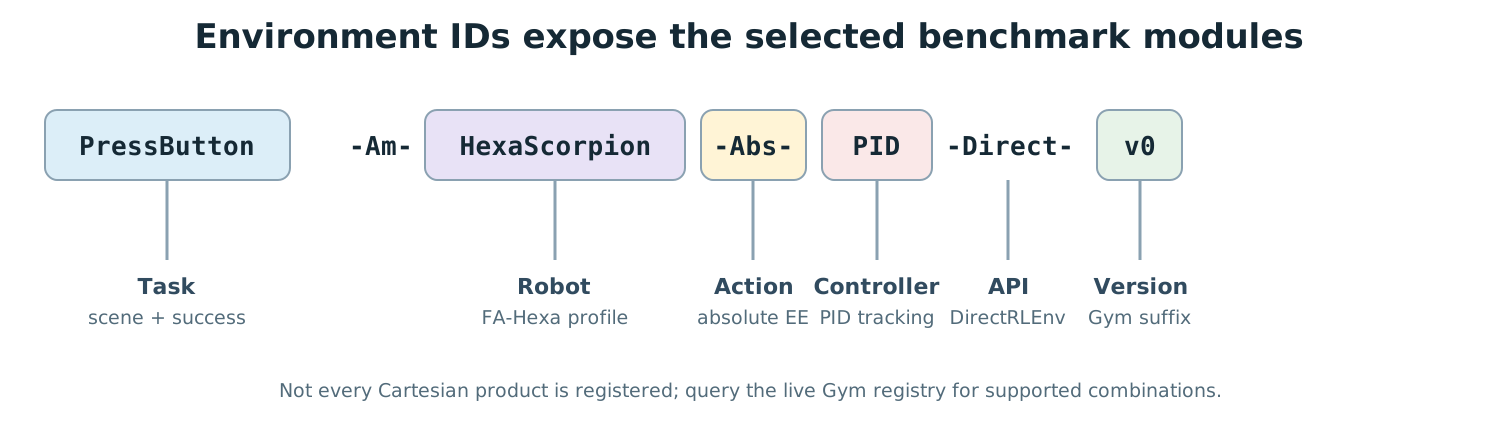
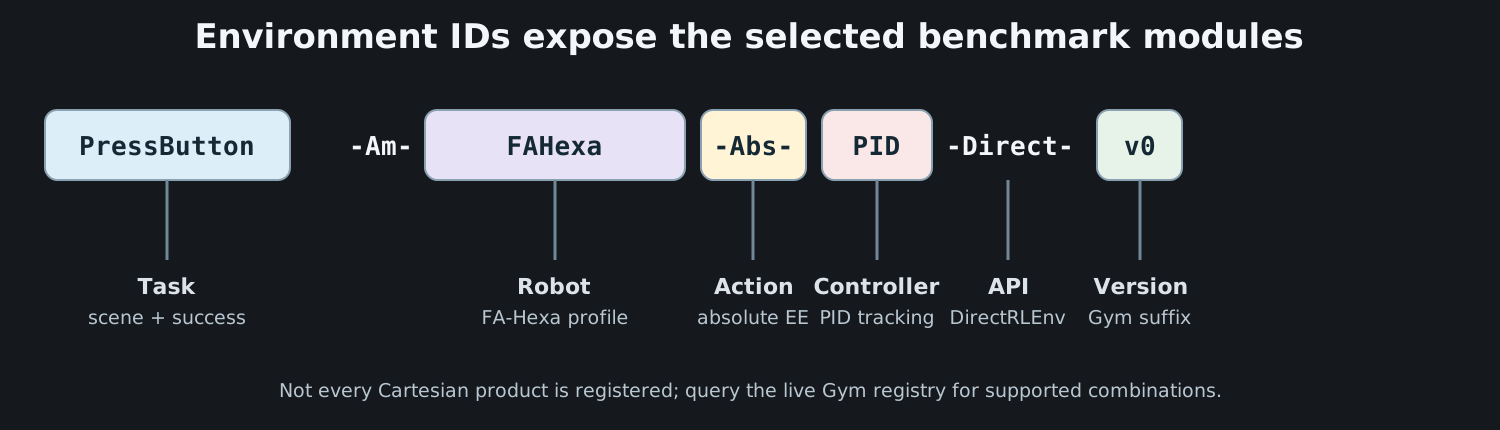
Naming pattern
The BaseJoint interface adds one token:
| Segment | Values used by the maintained suite | Meaning |
|---|---|---|
Task |
PressButton, PegInHole, FrameAssembly, and the other names in Tasks and Scenes |
Task family and scene logic |
Robot |
EE, UAQuad, UAHexa, FAHexa, OmniHexa |
EE oracle, UA-Quad, UA-Hexa, FA-Hexa, or Omni-Hexa profile |
Action |
Abs or BaseJoint-Abs |
Public action representation |
Controller |
PID, L1, or MPC |
Low-level controller family |
Direct |
fixed token | Isaac Lab DirectRLEnv task |
v0 |
version suffix | Gym registration version |
Not every combination is registered. BaseJoint variants exist only for selected tasks and platforms, and whole-body MPC uses absolute EE targets on FAHexa. Treat the Gym registry as authoritative.
Discover the exact registry
Follow Find an Environment to launch the registry command and select an ID from the current checkout. This reference explains the returned IDs; the live Gym registry remains authoritative.
Maintained registration inventory
The 12 maintained public task prefixes are:
CabinetPickPlace  FrameAssembly   LemonHarvesting  NDT
OpenDoor          PegInHole       PressButton      PullLever
PushSlider        RotateValve     TossBall         WipeWindow
Every task prefix is registered with these 8 suffixes:
| Robot | Registered suffixes |
|---|---|
| EE oracle | -Am-EE-Abs-PID-Direct-v0, -Am-EE-Abs-L1-Direct-v0 |
| OmniHexa | -Am-OmniHexa-Abs-PID-Direct-v0 |
| FAHexa | -Am-FAHexa-Abs-PID-Direct-v0, -Am-FAHexa-Abs-L1-Direct-v0, -Am-FAHexa-Abs-MPC-Direct-v0 |
| UAHexa | -Am-UAHexa-Abs-PID-Direct-v0 |
| UAQuad | -Am-UAQuad-Abs-PID-Direct-v0 |
Concatenate one task prefix and one suffix from the same row set. For example, WipeWindow plus -Am-UAQuad-Abs-PID-Direct-v0 gives the registered ID WipeWindow-Am-UAQuad-Abs-PID-Direct-v0.
Selected tasks add these variants:
| Tasks | Additional suffixes |
|---|---|
PressButton, PushSlider, RotateValve |
-Am-FAHexa-BaseJoint-Abs-PID-Direct-v0, -Am-FAHexa-BaseJoint-Abs-L1-Direct-v0 |
LemonHarvesting, PressButton, PushSlider, RotateValve |
-Am-EE-Abs-PID-Direct-Fast-v0 |
This produces 106 maintained public IDs. The inventory is derived from the literal task_id registrations in the 12 maintained task packages. Development-only task packages are outside this public inventory.
Examples
PressButton-Am-EE-Abs-PID-Direct-v0
PressButton-Am-FAHexa-Abs-PID-Direct-v0
PressButton-Am-FAHexa-BaseJoint-Abs-L1-Direct-v0
PressButton-Am-FAHexa-Abs-MPC-Direct-v0
The first is the lightest task-logic check. The second adds a physical FA-Hexa, Pyroki IK, allocation, and PID tracking. The third makes the policy command base pose and arm joints directly. The fourth replaces the decoupled IK–tracking path with whole-body MPC.
The -Fast-v0 registrations are specialized scripted-policy configurations rather than the default starting point.